• Gantry Robot Manufacturer & Articulated Arm Integrator

How to Choose an MCB Assembly Robot?

Choosing a Mcb Assembly Robot is not simply a matter of comparing cycle times. The right system must place miniature components accurately, manage varied product models, and maintain consistent assembly quality across shifts. A misaligned contact or poorly seated spring can trigger rework that erases apparent speed gains.

The scale of industrial automation is growing. The International Federation of Robotics reported 553,052 industrial robot installations worldwide in 2022, a 5% increase from 2021, in its World Robotics 2023 report. That figure describes industrial robots broadly, not MCB-specific equipment. Still, it shows why manufacturers are examining automation more closely. Bill Gates, whose work has focused on technology and business, offered a useful caution: “Automation applied to an inefficient operation will magnify the inefficiency.” The principle matters here. A robot cannot fix unstable component feeding or unclear inspection criteria.

A sound selection process starts with the actual production task. Check the required output per hour, product range, changeover time, placement accuracy, and inspection method. Then inspect the physical details: feeder access, gripper reach, guarding, and space for maintenance. Ask suppliers for a sample run using your components, not only a polished demonstration. Request cycle-time data and defect results, and confirm how they were measured. Small data sets can mislead. That deserves a second look.

This guide explains how to compare robot configurations, evaluate integration and support, and calculate the full cost of ownership. It also considers an awkward reality: the technically impressive machine may not be the best fit for a factory’s operators, layout, or production mix.
How to Choose an MCB Assembly Robot?

Define Production Requirements for MCB Assembly

Before comparing an MCB assembly robot, translate the production plan into measurable requirements. Record target units per shift, operating hours, planned changeovers, and expected annual volume. Include the actual product mix: pole count, housing dimensions, terminal styles, and accessory options can affect handling. Small variations matter. Use observed cycle times, not only supplier estimates; feeding, screwdriving, inspection, and reject removal all take time. Keep a buffer for downtime and maintenance. Early estimates are often optimistic.

Specify which operations need automation and which checks require traceable records. An MCB line may need controlled component feeding, contact installation, screw tightening, marking, and electrical or mechanical checks. Define acceptance limits with process and quality teams, including how the station responds to a missing contact or out-of-range torque. Decide how operators load trays, clear faults, and change formats; a fast cell is not useful if routine recovery is confusing. Ask for cycle-time and repeatability data using a representative product mix. Then run a pilot with actual parts. Check reject rates, changeover time, maintenance access, and floor-space constraints. Future variants may arrive earlier than expected, so leave room for adjustment without buying capacity the plant cannot use.

Map the Assembly Tasks and Required Automation Level

Before choosing an MCB assembly robot, map each operation from component loading to finished-unit inspection. Watch the current process on the production floor. Note where operators place contacts, fit the arc chamber, tighten terminals, and verify trip mechanisms. Small details matter. Record cycle times, part orientation, fastener torque, and common stoppages. A hand-written note about a jammed feeder may reveal more than an average-speed figure.

Then match automation to the real work. Stable, high-volume products may justify automatic feeding, robotic placement, screwdriving, and in-line testing. Frequent model changes may call for adjustable fixtures, recipe-based settings, or a semi-automated station with operator loading. Consider which tasks require controlled force or precise alignment. Also note where people still make judgment calls, such as spotting a poorly seated component. A spreadsheet can miss that.

The task map will be incomplete at first. Operators often notice variations that process charts overlook, so review the map with them before setting requirements. Run a pilot using representative MCB models, not just the easiest one. Measure cycle time, changeover time, misfeeds, rework, and test failures across several shifts. The right automation level is the one that handles routine work reliably without making product changes unnecessarily difficult. A little uncertainty remains. That is useful.

Select Robot Configuration, End Effectors, and Vision Systems

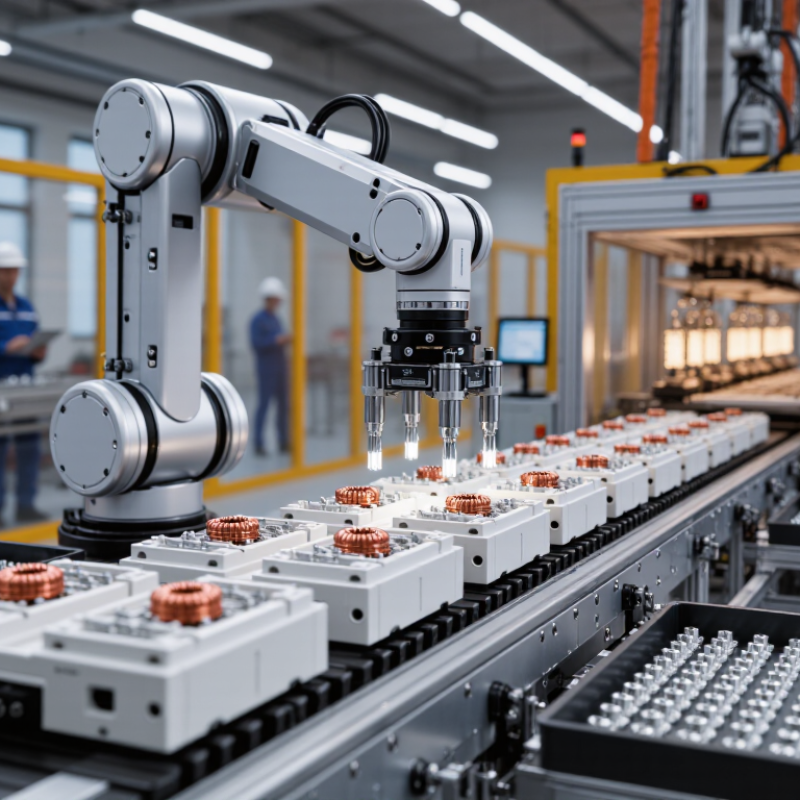
Choosing an MCB assembly robot starts with the product mix and required output, not a catalog speed figure. A fixed robot cell can suit a stable product range, while a flexible configuration helps when breaker sizes or assembly steps change. Check reach, payload, cycle time, and access for tool changes. Leave room for feeders, safety guarding, and maintenance. A compact layout may still make routine service awkward.

End effectors must grip small components without damaging plastic housings or shifting metal contacts. For screws, choose a driver with controlled torque and feedback; for pick-and-place tasks, test gripping force on real parts. Vision systems can verify component orientation, presence, and label position. Match camera placement and lighting to reflective metal surfaces and tight workspaces. Poor lighting causes false rejects. Validate detection across normal part variations, not just ideal samples. Early cycle estimates can be wrong until trials reveal jams or extra handling.

Tips: Run a pilot with actual MCBs and fasteners. Record mispicks, screw results, and changeover time. Ask operators to review access and recovery steps. No setup is perfect on paper; refine it after observing real production.

Check Safety, Quality Control, and Factory Integration

When choosing an MCB assembly robot, look beyond its cycle speed. Safety features should match the actual cell layout and operator tasks. Check for guarded access, interlocked doors, emergency stops, and clear recovery procedures. Ask how the robot behaves after a jam or power interruption. Small details matter. A well-designed system lets technicians reach common service points without entering hazardous areas.

Tips: Request a live safety demonstration with the intended tooling and parts. Review sample inspection records, reject handling, and changeover steps. Test it offline. Confirm that sensors can detect misplaced components before they reach the next station.

Quality control should be built into the process, not added as a final check. Vision systems can verify component presence and orientation, while monitored torque tools can record fastening results. Ask for traceable data linked to each production batch. Then inspect how the system flags uncertain readings; false rejects can waste time, but missed defects matter more. Integration deserves equal attention. Check compatibility with existing PLCs, conveyors, safety circuits, and production data systems. Share real part drawings and line constraints before requesting a proposal. A robot may meet its target in a clean demo, yet struggle with worn components or frequent product changes. I have seen planning overlook these small variations. Leave room for a practical factory trial.

How to Choose an MCB Assembly Robot? - Check Safety, Quality Control, and Factory Integration

Evaluation area What to check Practical acceptance points Evidence to request
Machine safety Risk assessment, guarding, interlocks, emergency stops, and safe access for setup and maintenance. The safety design should be based on a documented risk assessment and applicable local regulations. Review relevant standards such as ISO 10218, ISO 13849-1, and IEC 60204-1 where applicable. Risk assessment, safety-function details, electrical schematics, validation records, and a demonstration of safety devices.
Assembly quality Correct part orientation, component presence, terminal handling, screw fastening, and rejection of defective assemblies. Define acceptance limits from the product drawing and process specification. Fastening torque and inspection limits should be product-specific, not assumed to be universal. Control plan, sample inspection results, fastening-tool calibration records, and agreed pass/fail criteria.
In-line inspection Vision or sensor checks for missing, misplaced, damaged, or incorrectly oriented components. Challenge the inspection system with known good and known defective samples. Confirm that failed units are automatically identified and contained. Inspection challenge-test results, defect images where available, reject handling demonstration, and traceable inspection records.
Output and cycle time Required good units per shift, actual cycle time, planned downtime, and time needed for replenishment or changeover. Set the target from demand and available production time. Validate sustained output during a representative run rather than relying only on a theoretical robot cycle time. Cycle-time study, run-off results using representative parts, and a stated method for calculating availability and good-unit output.
Product and tooling flexibility Supported MCB frame sizes, pole configurations, accessory variants, recipes, and fixture adjustments. List every intended product variant before design approval. Confirm whether format changes require tooling, software recipes, or manual adjustments. Variant matrix, changeover procedure, tooling list, and a witnessed changeover using representative products.
Factory integration PLC and line interface, upstream/downstream handshakes, production data, alarms, and traceability requirements. Agree on signal lists, data ownership, network requirements, and recovery behavior before installation. Confirm compatibility with the plant’s approved interfaces and cybersecurity rules. Interface specification, I/O list, sample production records, and an integration test plan.
Testing and compliance Electrical checks and product-specific tests required by the applicable MCB product standard and customer specification. Confirm whether testing is performed in the cell, elsewhere on the line, or by a separate station. Applicable requirements may include IEC 60898-1 or IEC 60947-2, depending on the product and intended use. Test-method specification, calibration records, sample test reports, and a documented response to failed results.
Maintenance and support Access to wear parts, fault diagnostics, spare-parts availability, training, and maintenance documentation. Check that routine maintenance can be completed safely and that operators can identify common faults. Agree on support arrangements and critical spare-parts lead times. Maintenance schedule, spare-parts list, training plan, manuals, and fault-recovery demonstration.

Note: Requirements depend on the MCB design, production volume, applicable regulations, and factory standards. Confirm final safety and quality criteria with qualified specialists and the relevant product documentation.

Compare Suppliers, Support, and Total Cost of Ownership

An MCB assembly robot should be compared by the work it can reliably perform, not only its purchase price. Ask each supplier to demonstrate your actual breaker models, component tolerances, and target production mix. Watch a full changeover, not just a fast production run. Record cycle time, rejected parts, and manual interventions during the trial. Small pauses matter.

Supplier support can shape the machine’s real availability. Check where technicians are based, how quickly they respond, and which spare parts are stocked locally. Ask for a sample maintenance schedule and clear training plans for operators and technicians. A detailed handover helps, but it cannot replace practical fault-finding skills. Request contactable customer references with similar product volumes, and ask what problems arose after installation.

Calculate total cost of ownership across the expected service life. Include tooling, integration, software updates, energy use, preventive maintenance, and planned downtime. Compare these costs against measured output and reject rates, rather than best-case figures. Your estimate will still be imperfect. Supplier forecasts may assume steady demand, clean components, and smooth changeovers; your factory may not. Use conservative assumptions, then test the most uncertain costs before choosing a system.