What Is the Best Robotic Arm Design for 2026?
The best robotic arm design for 2026 is not a single shape or configuration. It is the design that fits its task, workspace, payload, and safety requirements. A compact six-axis arm may suit a crowded assembly cell, while a SCARA arm can handle fast, flat-plane pick-and-place work. The right choice becomes visible in small details: reach around a fixture, cable routing near a wrist joint, and repeatability after thousands of cycles. No design wins everywhere.
Robotics pioneer Rodney Brooks has observed, “The world is not a very predictable place.” That warning matters to robotic arm design. Real workcells contain shifting parts, glare, vibration, and occasional misalignment. A strong design accounts for these conditions through suitable sensors, gripper options, and controls, rather than relying on a perfect production line. Engineers should also compare payload at full extension, not just the headline capacity. That number can change the whole selection.
This guide examines arm geometry, joint layout, materials, control systems, and integration costs. It also weighs collaborative arms against traditional industrial models, where speed and reach may matter more than close human interaction. Some trade-offs remain stubborn. A lighter arm can improve responsiveness, yet may limit stiffness under load. I would question any “best” ranking that ignores maintenance access or the cost of downtime. Those details are less exciting. They are often decisive. The useful answer is a design matched to measurable needs, tested under realistic conditions, and reviewed again when the task changes.
What Defines a Robotic Arm Design in 2026?
What defines a robotic arm design in 2026 is not its silhouette, but how reliably it performs a real task. Reach, payload, repeatability, speed, and mounting position must match the workcell. A 10-kilogram payload rating, for example, is not enough if a long tool creates excessive wrist torque. The gripper, cables, sensors, and workpiece all affect the load. Small details matter.
Scale matters. The International Federation of Robotics’ World Robotics 2024 reports 541,302 industrial robots installed worldwide in 2023, with 4,281,585 operating globally. Its 2023 report recorded 553,052 installations in 2022. These figures point to a mature field where a design must fit existing production, not merely look advanced. Useful design reviews examine cycle time, energy use, service access, and safe interaction alongside motion performance.
A good specification separates repeatability from absolute accuracy; they are not interchangeable. It also records the test conditions, tool mass, and operating speed behind each claimed result. A tidy CAD model can still hide awkward cable bends or unreachable fasteners. That happens. I would test the arm with the actual end-effector and a representative workpiece before locking the layout. A little doubt helps. The best design is the one operators can maintain, and engineers can verify under real conditions.
What Is the Best Robotic Arm Design for 2026?
Typical degrees of freedom by arm architecture. Common configurations range from three-axis Cartesian and Delta arms to six-axis articulated arms. The best design depends on the task: more degrees of freedom can improve orientation flexibility, while simpler architectures can suit repetitive, constrained movements. Payload, reach, accuracy, cycle time, and safety requirements should also guide selection.
Key Components and Motion Architectures
A robotic arm is more than a chain of joints.
Its actuators, bearings, encoders, wiring, and tool interface must work as one system. A six-axis articulated arm can reach around fixtures and approach parts from varied angles. A SCARA design often suits fast, planar assembly, while a Cartesian arm offers straightforward movement along three axes. No architecture is best for every cell.
Joint choice shapes precision and maintenance. Harmonic or cycloidal reducers can provide compact torque, but stiffness, backlash, heat, and service access still matter. Direct-drive joints avoid reduction stages, yet their motors may add cost and mass. Small details count. A cable bundle crossing a wrist can snag during repeated turns, so routing and bend radius deserve early attention. A neat CAD model can still hide a clumsy wrist.
Match reach and payload to the actual tool, part, and acceleration profile, not just the workpiece weight. A gripper holding a metal housing creates different wrist loads from a light vacuum cup. Encoders track joint position; force or vision sensors can help with contact and alignment, but they need calibration and clear operating conditions. Seven-axis arms add redundancy for avoiding obstacles, though extra joints complicate planning and control. This trade-off is easy to underestimate. Real cycle testing may reveal vibration, cable wear, or awkward access that simulations miss.
How Performance, Safety, and Cost Are Evaluated
What Is the Best Robotic Arm Design for 2026?
How Performance, Safety, and Cost Are Evaluated
The best design depends on the task, not the biggest payload number. Evaluate payload at the arm’s full reach, where lifting capacity may drop. Check cycle time, repeatability, and the space needed for the arm, cables, and end tool. A practical test is to run the intended motion with a representative load, then measure whether it meets production needs. Fast is not always useful.
Safety needs equal attention. Review pinch points, stopping behavior, emergency access, and how the system responds after a fault. A guarded cell may suit a fixed process; shared workspaces need a more careful risk assessment and suitable protective measures. Keep records of test conditions and maintenance. A tidy spreadsheet can miss awkward cable movement or a tool that shifts under load. I would not treat any single demonstration as proof of long-term reliability.
Tips: Compare total ownership cost, including integration, training, tooling, energy, and maintenance. Ask for repeatability data under your actual operating conditions. Leave room for uncertainty: real shifts rarely match a perfect demo.
Leading Design Approaches for Different Applications
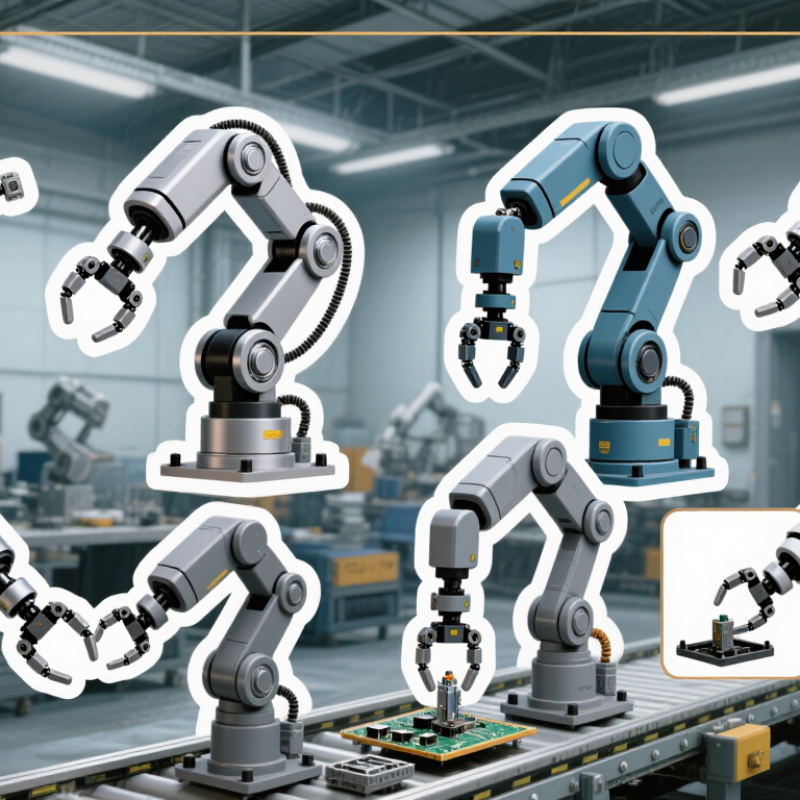
The best robotic arm design for 2026 depends on the task, workspace, and acceptable level of risk. For fast pick-and-place, a delta arm can move small items quickly across a compact area. SCARA designs suit repetitive assembly, such as placing a connector into a fixture. For varied paths and heavier loads, a six-axis articulated arm offers more reach and orientation control. More joints also mean more setup and calibration.
Tips: Measure the real work envelope, including grippers and cables. Test cycle time with the actual object, not a lightweight substitute. Check reach at awkward angles, where speed and stiffness can change. A small bench test often reveals problems sooner than a polished simulation.
For machine tending or shared work areas, prioritize predictable stopping, clear sensing, and easy recovery after a fault. Match the arm’s payload rating to the tool and part together; ignoring gripper weight is a common planning mistake. Also consider maintenance access. A design that looks compact on a drawing may leave little room to reach a joint or replace a cable. There is no universal winner. Simulations help, but they can miss floor vibration, cable drag, or inconsistent part placement. Plan time for adjustments.
Choosing an Arm Design for Specific Tasks and Environments
A robotic arm should be chosen around the work, not its appearance in a specification sheet.
For repeated pick-and-place on a flat surface, a SCARA design can move quickly while keeping its footprint compact. A six-axis arm suits tasks that need angled approaches, such as placing a component inside a deep housing. For straight-line movement between fixed points, a Cartesian system may be easier to position and maintain.
Space is tight. Measure the full reach, including the gripper and cables, before deciding where the base will sit.
The environment changes the choice. In a washdown area, exposed joints and cable routes may create cleaning problems; near fine dust, covers and service access deserve careful attention.
Check payload with the actual tool attached, not just the object’s weight. A heavier gripper can reduce usable capacity and slow movement. Match repeatability to the task: a broad placement tolerance rarely needs the same precision as inserting a small pin.
Review cycle speed, mounting, operator access, and recovery after a stop. A tidy CAD model can still mislead.
I would test the proposed reach using a cardboard mock-up or a slow, supervised trial. It may feel less polished, but it can reveal collisions a drawing missed.